 |
|

|
|
Certification


- I'm Online Chat Now
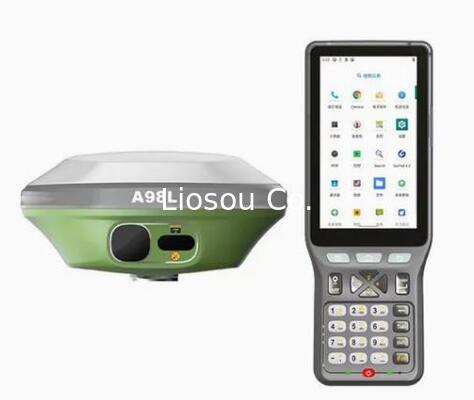
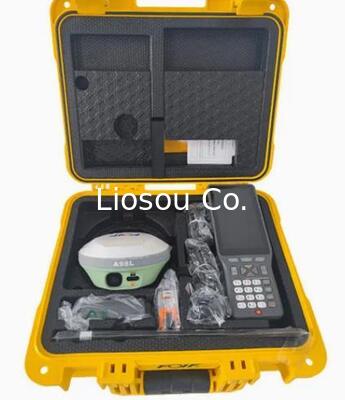
Global version FOIF A98L 1408 channels laser AR function gnss rtk topographic equipment
Product Details:
Payment & Shipping Terms:
|
Detailed Product Description
| Name And Model: | A98L | Horizontal: | 2.5mm+0.5ppm RMS |
|---|---|---|---|
| Vertical: | 5mm+0.5ppm RMS | Transport Package: | Case And Carton |
| Channels: | 1408 | IMU: | Yes |
| Mian Board: | UM980 | Laser: | Green Laser Dual HD Camera AR Stakeout |
| Data Update Frequency: | Supports 50Hz Output | Operation System: | Linux |
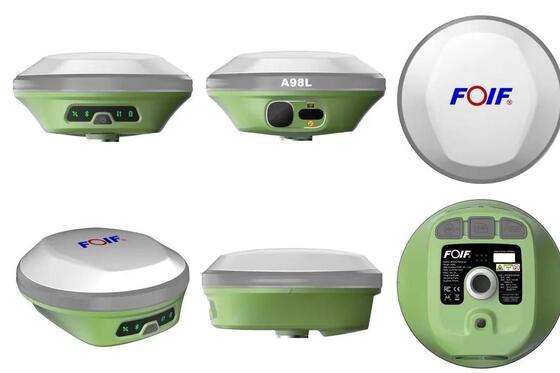
Global version 1408 channels laser AR function gnss rtk topographic equipment FOIF A98L With Green Laser Dual HD Camera AR Stakeout

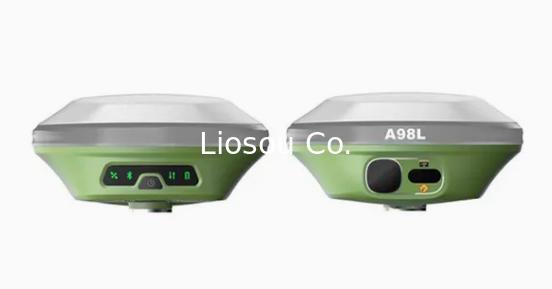
The A98L is a laser dual-camera RTK product that supports full-system and full-frequency high-precision positioning for BDS/GPS/GLONASS/Galileo/QZSS. It integrates a visible laser, visual imaging, and IMU inertial navigation module, with front and bottom high-definition cameras, making surveying worry-free!
Features :
1.Green visible laser ranging with image marking
2.All-constellation, all-frequency signal tracking – full support for BeiDou Satellite Navigation System
3.Dual-camera real-world stakeout, equipped with IMU module & 30FPS high-frame-rate camera
4. Integrated transceiver radio – multi-protocol support, channel detection, and signal ID recognition
Technical Parameters:
| GNSS Engine | Satellite tracking | GPS: L1 C/A, L1C, L2P(Y), L2C, L5 |
| GLONASS: G1,G2,G3 | ||
| BDS: B1I, B2I, B3I,B1C, B2a,B2b | ||
| Galileo: E1, E5A, E5B, E6 | ||
| NavlC (IRNSS): L5 | ||
| SBAS: L1C/A, | ||
| PPP:B2B-PPP I E6-HAS | ||
| Channel | 1408 | |
| Data update frequency | Supports 50Hz output | |
| Positioning frequency | 1Hz 2Hz 5Hz 10Hz 20Hz 50Hz | |
| Cold start | <12 seconds | |
| Initialization time | <5 seconds | |
| Initialization reliability | >99.9% | |
| Tilt survey accuracy | ≤2cm within 60°tilt | |
| Time accuracy | 20ns | |
| RTK accuracy | H: ±8.0 mm+1 ppm V: ±15.0mm+1ppm | |
| Static accuracy | H: ±2.5 mm+0.5 ppm V: ±5.0mm+0.5ppm | |
| Single point accuracy | H:1.5m V:2.5m | |
| Differential accuracy | H:0.4m V:0.8m | |
| Laser module | Laser ranging distance | 0.1-50m |
| Laser ranging resolution | 1mm | |
| laser ranging accuracy | 2mm @ 10 | |
| Laser Measurement accuracy(pane) | 2cm within 5m/3cm within 10m When IMU reaches the optimal initilazation state | |
| Battery | Battery life | Static 20H, Rover 16H, Base 10H |
| Power supply | 9v/2A,5V/2A MAX 18W,3.6V-13600mAh | |
| Physical | Shell material | Magnesium aluminum alloy |
| Button | Power button | |
| Indicator | Satellites, datalink,battery | |
| Operating temperature | -30ºC~+65ºC | |
| Storage temperature | -40ºC~+80ºC | |
| Water/dust proof | IP68 | |
| Operating humidity | 99.90%non-condensing | |
| Shock | 1.8m pole drop resistant in normal temperature | |
| System | Operation system | Linux |
| Internal memory | 8GB | |
| Data transmission | 4G/WIFI/Radio | |
| Radio | 1w | |
| Radio frequency | 410-470MHZ | |
| Air baudrate | 1,920,096,004,800 | |
| Camera | Number of lenses | 2 |
| Lens field of view | 83.4°(front/bottom) | |
| sensor pixel | 2 megapixe(front/bottom) | |
| Camera focal length | 5m(front) 2m(bottom) | |
| Sensor resolution | 1920*1080 |
Contact Details
Shanghai Liosou Technology Co.Ltd
Contact Person: Ms. Rebecca Zhou
Tel: +86-18221338069
Other Products
-
STONEX S6II Gnss Receiver High Performance Professional Stonex Gnss Receiver with High Capacity Battery
-
High Precision Survey Instruments Stonex S9II GNSS RTK GPS Receiver Base and Rover with UM980 main board and 1408 channels Tilt sensor IMU function
-
Stonex S3AR Gnss Rtk Receiver GPS Surveying Instrument Ar Lofting GPS Rtk
-
New Model Foif A66MAX GNSS RTK Laser GPS Receiver for Construction
-
Hi-Target V98 RTK GNSS RTK GPS Receiver with UHF Radio for Engineering Survey and Stakeout with Removable Battery
-
Hi-target VRTK2/VRTK GNSS RTK GPS Dual Cameras for Image Survey and Live View Stakeout